13 / 16
Stepper Motor: Steps per Revolution
Compare step counts in a 2048-step-per-turn model. Calculate quarter and half turns and watch the motor advance through its sequence.
Run this experiment →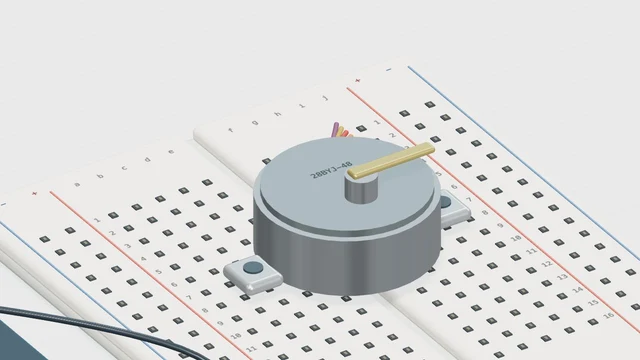
Why it’s here
Connect step count with angular displacement.
How it works
The example assumes 2048 steps per full rotation. Therefore 512 steps is one quarter-turn, or 90°. The model repeats a command followed by a pause, matching the example loop.
Try it
- Open this experiment
- Run with 512 steps, then try 1024. Compare the angular travel during one movement sequence.
Connections
- D8, D10, D9, D11 — Driver input sequence
- External supply — Motor power, not GPIO
Example sketch
#include <Stepper.h>
Stepper wheel(2048, 8, 10, 9, 11);

void setup() {
  wheel.setSpeed(10);
}

void loop() {
  wheel.step(512);
  delay(1000);
}
Check your understanding
How far does 512 steps move this 2048-step model?
Show the answer
A quarter turn, or 90°. The 2048 value belongs to this lesson’s model; use your actual motor and gearing specifications on hardware.